مجموعة بيانات VisDrone
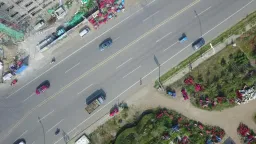
تُعد مجموعة بيانات VisDrone معيارًا واسع النطاق لصور الطائرات المسيّرة، وتوفر مجموعة الكشف الفرعية فيها (VisDrone2019-DET) عدد 8,629 صورة جوية — 6,471 للتدريب، و548 للتحقق، و1,610 للاختبار التطويري — مشروحة بعشر فئات من الأجسام من أجل الكشف عن الأجسام. أنشأها فريق AISKYEYE في مختبر التعلم الآلي وتنقيب البيانات بجامعة تيانجين في الصين.
شاهد: كيفية تدريب Ultralytics YOLO على مجموعة بيانات VisDrone | الاكتشاف الجوي | شرح تعليمي كامل 🚀
تتألف مجموعة VisDrone المعيارية الكاملة من 288 مقطع فيديو (261,908 إطارًا) و10,209 صور ثابتة التُقطت بكاميرات مثبتة على طائرات مسيّرة في 14 مدينة مختلفة في أنحاء الصين، وتغطي بيئات حضرية وريفية، ومشاهد قليلة الأجسام أو مزدحمة، وظروفًا متنوعة من الطقس والإضاءة. وتضم إطاراتها أكثر من 2.6 مليون صندوق إحاطة مشروح يدويًا، إلى جانب سمات إضافية مثل مدى وضوح المشهد وفئة الجسم ودرجة الاحتجاب. يستخدم إعداد Ultralytics VisDrone.yaml المجموعة الفرعية للصور الثابتة VisDrone2019-DET من هذا المعيار.
الميزات الرئيسية#
- أجسام صغيرة وكثيفة: تجعل المناظير الجوية الأهداف صغيرة ومزدحمة؛ إذ تحتوي صور التحقق البالغ عددها 548 وحدها على 38,759 صندوقًا موسومًا، بمتوسط يقارب 70 جسمًا في الصورة.
- تنوع المشاهد: صور من 14 مدينة صينية تغطي مواقع حضرية وريفية، والنهار والليل، وظروفًا جوية مختلفة.
- تعليقات توضيحية غنية: أكثر من 2.6 مليون صندوق في المعيار الكامل، مع سمات للاحتجاب والوضوح.
- تقسيمات محددة مسبقًا: تقسيمات ثابتة إلى تدريب / تحقق / اختبار تطويري (6,471 / 548 / 1,610 صورة) لضمان اتساق التقييم.
بنية مجموعة البيانات#
يشمل إعداد Ultralytics لـVisDrone مجموعة الصور الفرعية VisDrone2019-DET، المقسمة إلى ثلاثة أجزاء:
| المجموعة الفرعية | الصور | الوصف |
|---|---|---|
| التدريب | 6,471 | صور جوية موسومة تُستخدم لتدريب الكاشف |
| التحقق | 548 | صور تُستخدم للتقييم أثناء التطوير |
| الاختبار التطويري | 1,610 | صور محجوبة من التدريب للتقييم النهائي للنموذج المدرّب |
هناك تقسيم رابع هو test-challenge (1,580 صورة)، تحتفظ به مسابقة VisDrone ولا يُنزّل؛ لذلك يبلغ إجمالي مجموعة DET الكاملة 10,209 صور.
تتضمن مجموعة البيانات تعليقات توضيحية لعشر فئات من الأجسام: مشاة، أشخاص، دراجة، سيارة، شاحنة صغيرة، شاحنة، دراجة ثلاثية العجلات، دراجة ثلاثية العجلات ذات مظلة، حافلة، ودراجة نارية. تميّز VisDrone بين المشاة (شخص واقف أو يمشي) والأشخاص (شخص في أي وضعية أخرى).
عند الاستخدام الأول، يحوّل برنامج التنزيل التعليقات التوضيحية الأصلية في VisDrone إلى تنسيق YOLO، متجاوزًا المناطق المصنفة على أنها متجاهلة (ويستبعد بذلك أيضًا فئة «أخرى» غير المستخدمة).
التطبيقات#
تجعل المشاهد المكتظة والأهداف الصغيرة في VisDrone منها معيارًا قياسيًا لـاكتشاف الكائنات الصغيرة من المناظير الجوية. وتشمل تطبيقات الرؤية الحاسوبية الشائعة للطائرات المسيّرة:
- مراقبة حركة المرور وإحصاء المركبات باستخدام UAVs
- تحليل الحشود ومراقبة السلامة العامة
- فحص البنية التحتية ومواقع البناء
- أبحاث الرؤية الحاسوبية حول اكتشاف الأجسام الصغيرة في المشاهد المزدحمة
للاطلاع على معايير أخرى للصور الجوية، راجع مجموعة بيانات xView المخصصة للأقمار الصناعية أو مجموعة بيانات DOTA-v2 ذات الصناديق الموجّهة.
ملف YAML لمجموعة البيانات#
يحدد الملف VisDrone.yaml إعداد مجموعة البيانات، بما في ذلك مساراتها وأسماء الفئات والبرنامج النصي للتنزيل والتحويل التلقائي. ويُصان الملف في مستودع Ultralytics على https://github.com/ultralytics/ultralytics/blob/main/ultralytics/cfg/datasets/VisDrone.yaml.
# Ultralytics 🚀 AGPL-3.0 License - https://ultralytics.com/license

# VisDrone2019-DET dataset https://github.com/VisDrone/VisDrone-Dataset by Tianjin University
# Documentation: https://docs.ultralytics.com/datasets/detect/visdrone
# Example usage: yolo train data=VisDrone.yaml
# parent
# ├── ultralytics
# └── datasets
#     └── VisDrone ← downloads here (~2 GB)

# Train/val/test sets as 1) dir: path/to/imgs, 2) file: path/to/imgs.txt, or 3) list: [path/to/imgs1, path/to/imgs2, ..]
path: VisDrone # dataset root dir
train: images/train # train images (relative to 'path') 6471 images
val: images/val # val images (relative to 'path') 548 images
test: images/test # test-dev images (optional) 1610 images

# Classes
names:
  0: pedestrian
  1: people
  2: bicycle
  3: car
  4: van
  5: truck
  6: tricycle
  7: awning-tricycle
  8: bus
  9: motor

# Download script/URL (optional) ---------------------------------------------------------------------------------------
download: |
  import os
  from pathlib import Path
  import shutil

  from ultralytics.utils.downloads import download
  from ultralytics.utils import ASSETS_URL, TQDM

  def visdrone2yolo(dir, split, source_name=None):
      """Convert VisDrone annotations to YOLO format with images/{split} and labels/{split} structure."""
      from PIL import Image

      source_dir = dir / (source_name or f"VisDrone2019-DET-{split}")
      images_dir = dir / "images" / split
      labels_dir = dir / "labels" / split
      labels_dir.mkdir(parents=True, exist_ok=True)

      # Move images to new structure
      if (source_images_dir := source_dir / "images").exists():
          images_dir.mkdir(parents=True, exist_ok=True)
          for img in source_images_dir.glob("*.jpg"):
              img.rename(images_dir / img.name)

      for f in TQDM((source_dir / "annotations").glob("*.txt"), desc=f"Converting {split}"):
          img_size = Image.open(images_dir / f.with_suffix(".jpg").name).size
          dw, dh = 1.0 / img_size[0], 1.0 / img_size[1]
          lines = []

          with open(f, encoding="utf-8") as file:
              for row in [x.split(",") for x in file.read().strip().splitlines()]:
                  if row[4] != "0":  # Skip ignored regions
                      x, y, w, h = map(int, row[:4])
                      cls = int(row[5]) - 1
                      # Convert to YOLO format
                      x_center, y_center = (x + w / 2) * dw, (y + h / 2) * dh
                      w_norm, h_norm = w * dw, h * dh
                      lines.append(f"{cls} {x_center:.6f} {y_center:.6f} {w_norm:.6f} {h_norm:.6f}\n")

          (labels_dir / f.name).write_text("".join(lines), encoding="utf-8")

  # Download (ignores test-challenge split)
  dir = Path(yaml["path"])  # dataset root dir
  urls = [
      f"{ASSETS_URL}/VisDrone2019-DET-train.zip",
      f"{ASSETS_URL}/VisDrone2019-DET-val.zip",
      f"{ASSETS_URL}/VisDrone2019-DET-test-dev.zip",
      # f"{ASSETS_URL}/VisDrone2019-DET-test-challenge.zip",
  ]
  download(urls, dir=dir, threads=4)

  # Convert
  splits = {"VisDrone2019-DET-train": "train", "VisDrone2019-DET-val": "val", "VisDrone2019-DET-test-dev": "test"}
  for folder, split in splits.items():
      visdrone2yolo(dir, split, folder)  # convert VisDrone annotations to YOLO labels
shutil.rmtree(dir / folder) # cleanup original directoryالاستخدام#
تُنزّل VisDrone تلقائيًا عند التدريب لأول مرة — ثلاثة أرشيفات يبلغ مجموع حجمها نحو 2 GB — وتحتاج إلى نحو 4 GB من المساحة الحرة على القرص أثناء فك الضغط والتحويل.
لتدريب نموذج YOLO26n على مجموعة بيانات VisDrone لمدة 100 حقبة وبحجم صورة 640، يمكنك استخدام مقتطفات الشيفرة التالية.
from ultralytics import YOLO
# تحميل نموذج
model = YOLO("yolo26n.pt") # تحميل نموذج مدرّب مسبقًا (موصى به للتدريب)
# درّب النموذج - ستُنزل مجموعة البيانات تلقائيًا عند التشغيل الأول
results = model.train(data="VisDrone.yaml", epochs=100, imgsz=640)لتوسيم صور جوية إضافية وإدارة عمليات تدريب VisDrone في متصفحك، استخدم منصة Ultralytics.
البيانات النموذجية والتعليقات التوضيحية#
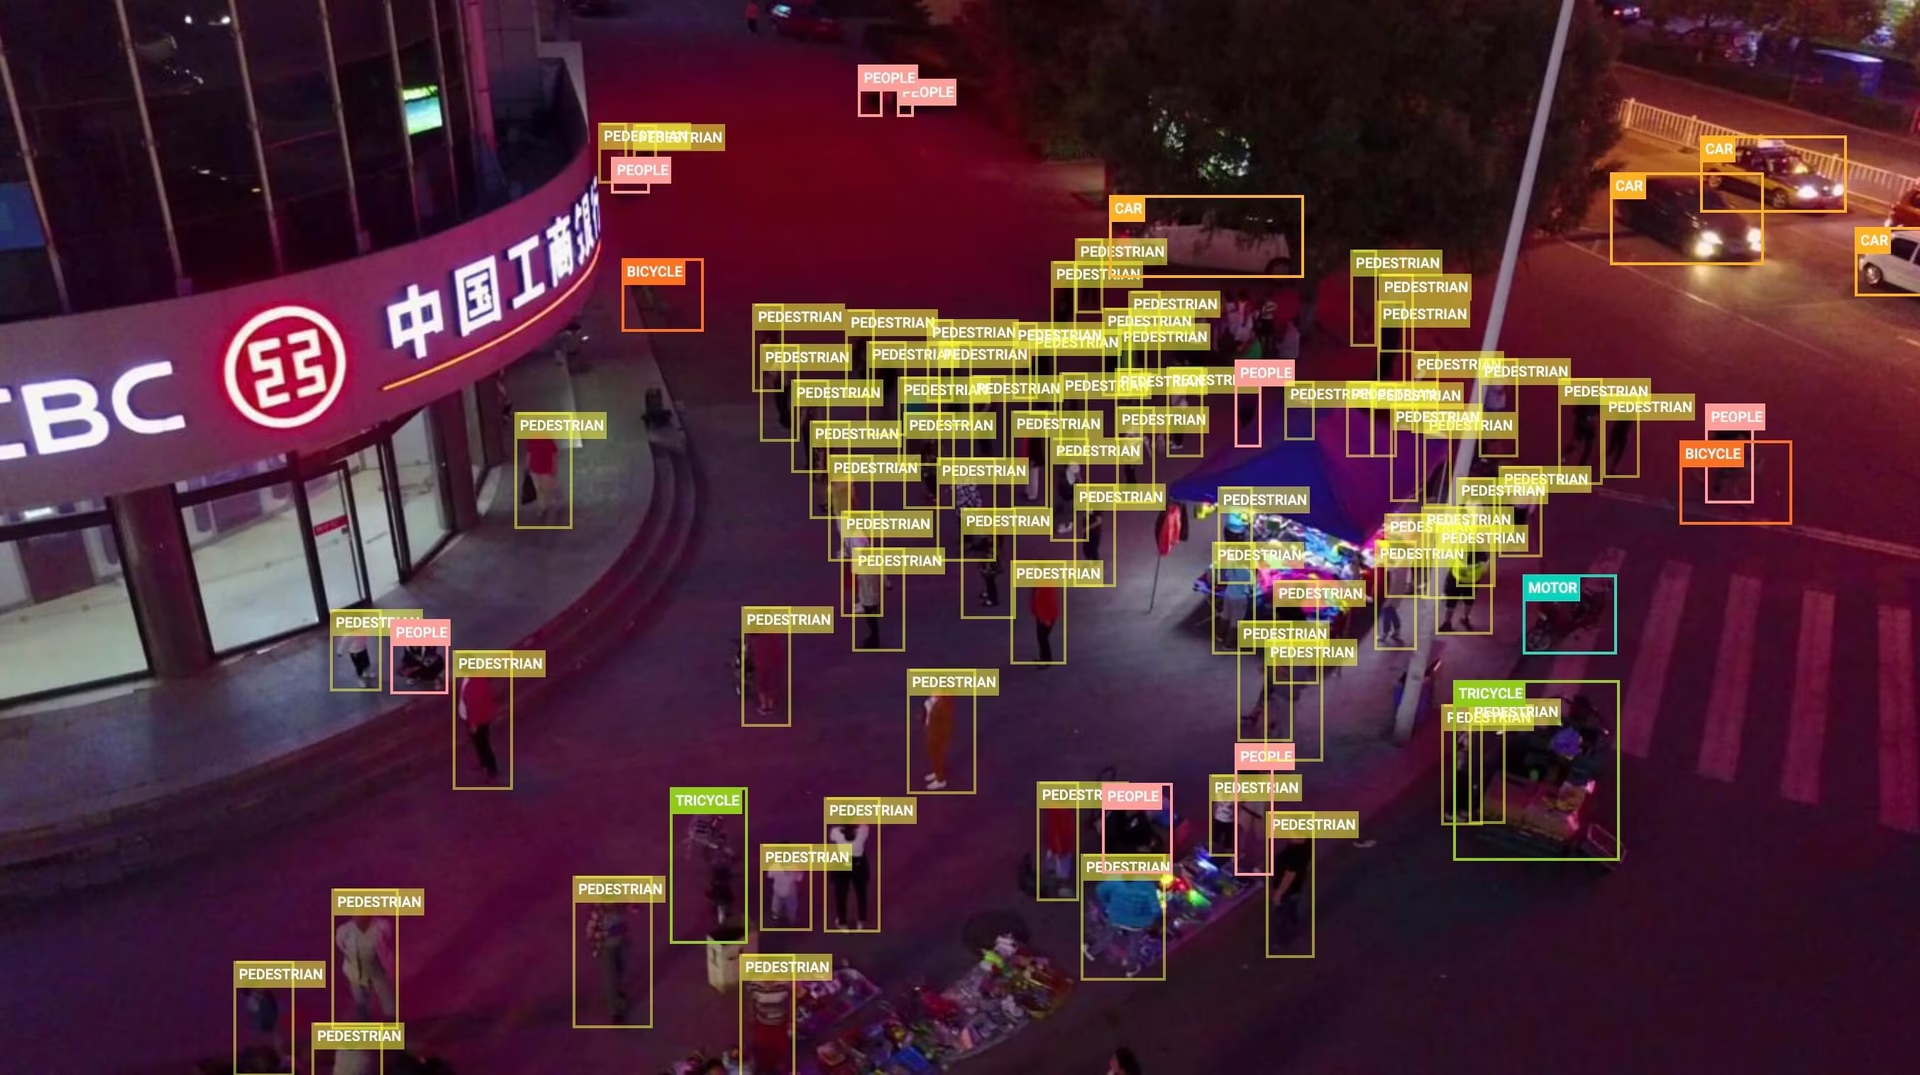
تُظهر العينة أدناه مشهدًا نموذجيًا من VisDrone: منظورًا جويًا لطريق مزدحم تظهر فيه المشاة والمركبات كأهداف صغيرة ومتقاربة، يحجب بعضها بعضًا جزئيًا.
الاستشهادات والشكر والتقدير#
إذا استخدمت مجموعة بيانات VisDrone في أبحاثك أو أعمال التطوير، فيُرجى الاستشهاد بالورقة البحثية التالية:
@ARTICLE{9573394,
  author={Zhu, Pengfei and Wen, Longyin and Du, Dawei and Bian, Xiao and Fan, Heng and Hu, Qinghua and Ling, Haibin},
  journal={IEEE Transactions on Pattern Analysis and Machine Intelligence},
  title={Detection and Tracking Meet Drones Challenge},
  year={2022},
  volume={44},
  number={11},
  pages={7380-7399},
  doi={10.1109/TPAMI.2021.3119563}}
نود الإشادة بفريق AISKYEYE في مختبر التعلم الآلي وتنقيب البيانات بجامعة تيانجين في الصين، لإنشاء مجموعة بيانات VisDrone وصيانتها. لمزيد من المعلومات، تفضّل بزيارة مستودع VisDrone Dataset على GitHub.
الأسئلة الشائعة#
تُستخدم VisDrone لتدريب الكواشف وتقييمها على الصور الملتقطة بالطائرات المسيّرة، حيث تكون الأجسام صغيرة وكثيفة وتُرى من الأعلى. ويجعل الجمع بين المناظير الجوية والمشاهد المزدحمة والظروف المتنوعة منها بيئة اختبار معيارية لمراقبة حركة المرور باستخدام UAVs، وتحليل الحشود، وأبحاث الكشف عن الأجسام الصغيرة.
يتضمن إعداد Ultralytics لـVisDrone عدد 8,629 صورة: 6,471 للتدريب، و548 للتحقق، و1,610 للاختبار (test-dev). وتشترك جميع التقسيمات في الفئات العشر نفسها: مشاة، أشخاص، دراجة، سيارة، شاحنة صغيرة، شاحنة، دراجة ثلاثية العجلات، دراجة ثلاثية العجلات ذات مظلة، حافلة، ودراجة نارية. راجع بنية مجموعة البيانات للاطلاع على التفاصيل الكاملة.
تُنزّل VisDrone تلقائيًا عند التدريب لأول مرة باستخدام
data="VisDrone.yaml"، ولا تتطلب أي خطوات يدوية. يجلب البرنامج النصي ثلاثة أرشيفات (نحو 2 GB) من أصول إصدارات Ultralytics على GitHub، ثم يحوّل التعليقات التوضيحية إلى تنسيق YOLO. ولا يتضمن التنزيل تقسيم test-challenge المحجوب الخاص بالمسابقة.درّب نموذج YOLO26n على VisDrone لمدة 100 حقبة وبحجم صورة 640:
مثال على التدريبfrom ultralytics import YOLO # تحميل نموذج model = YOLO("yolo26n.pt") # تحميل نموذج مدرّب مسبقًا (موصى به للتدريب) # تدريب النموذج results = model.train(data="VisDrone.yaml", epochs=100, imgsz=640)للاطلاع على الإعدادات التفصيلية، راجع صفحة التدريب ونصائح تدريب النماذج.
الأجسام في VisDrone صغيرة جدًا مقارنةً بالإطار — إذ لا يتجاوز حجمها غالبًا بضع عشرات من البكسلات — وتظهر في مجموعات كثيفة تحجب الأجسام فيها بعضها بعضًا بشدة، ما يشكّل تحديًا لكواشف الأجسام المضبوطة على الصور الملتقطة من مستوى الأرض. يتيح التدريب واستخراج التنبؤات بدقة أعلى (مثلًا باستخدام
imgsz=1280مع حجم دفعة أصغر) استعادة الأهداف الصغيرة، كما يقسّم تقسيم الصور عالية الدقة إلى رقع الصور الكبيرة كي تشغل الأجسام الصغيرة مساحة أكبر في كل نافذة استدلال.يغطي معيار VisDrone الكامل خمس مهام — كشف الأجسام في الصور، وكشف الأجسام في مقاطع الفيديو، وتتبع جسم واحد، وتتبع أجسام متعددة، وإحصاء الحشود — عبر 288 مقطع فيديو و10,209 صور ثابتة. ولا يغطي إعداد Ultralytics
VisDrone.yamlسوى مهمة كشف الأجسام في الصور (VisDrone2019-DET)، إذ ينزّل 6,471 صورة تدريب و548 صورة تحقق و1,610 صور اختبار تطويري.استشهد بالورقة البحثية «التحدي الذي يجمع بين الكشف والتتبع والطائرات المسيّرة» (IEEE TPAMI، المجلد 44، العدد 11، 2022، DOI 10.1109/TPAMI.2021.3119563)؛ يتوفر إدخال BibTeX الكامل في قسم الاستشهادات والشكر والتقدير أعلاه.


التعليقات24
اطرح سؤالًا، وشارك نتائجك، أو ساعد شخصًا آخر.
arpithavkhanapur1226-collab
Thank you for the suggestions. I’ve tried the recommended changes and checked the dataset, including removing the degenerate bounding box, but I’m still facing the NaN issue around epoch 30. The best mAP I’m getting is only around 33.2%, which is far below the expected performance. I’ve tried several approaches already, but I’m not able to figure out what is causing the instability. Could you please help me identify what might be going wrong or suggest what I should specifically check next? ,I have attached my code and result below ,I would really appreciate your guidance.
visdrone2.ipynb
 Paula DerrengerUltralytics
Please rerun a clean baseline with the official
VisDrone.yaml, pretrained weights, and defaults; after correcting annotations, delete all*.cachefiles in the dataset’slabelsdirectories, and restart the notebook kernel if Ultralytics was upgraded. If NaNs persist, share the complete text training log/traceback, exactmodel.train(...)arguments, Ultralytics version, and output fromyolo checks; also try a smaller learning rate and higherimgszsuch as1280, since VisDrone contains many tiny objects.
I’m training YOLOv12 on the VisDrone dataset, but I faced NaN losses after around epoch 29. I found a degenerate bounding box with zero height and removed it, but the NaN issue still occurred. I then tried DDPNet on VisDrone, but the validation performance started plateauing around epoch 14. Training is also very slow on a T4 (~4 hours for 12 epochs). Could you suggest what I should check or change to improve the training performance?
- Paula DerrengerUltralytics
After correcting every invalid/non-finite label and ensuring normalized boxes have positive width/height, delete all
*.cachefiles inside thelabelsdirectories before retraining. Establish a baseline with a pretrained Ultralytics model atimgsz=640; then inspectresults.png, per-class AP, and the confusion matrix before changing augmentation or resolution. VisDrone contains many tiny, dense objects, so higher resolution may improve accuracy but will substantially slow a T4; use ann/smodel and the largest stable batch first. If NaNs persist, please share the exact training command, complete text logs around the first NaN, Ultralytics version, andyolo checksoutput; see the VisDrone training guide and fine-tuning troubleshooting.
mslabdelhak29
Hello can you offre a pretrained model i need it and i dont have source to entrain for 100 epochs
 Glenn JocherUltralytics(تم التعديل)
Hi, we don’t currently provide an official YOLO model pretrained specifically on VisDrone, so the usual workflow is to start from a generic checkpoint like
yolo26n.ptand fine‑tune it on VisDrone; you can safely reduceepochs(e.g. 10–20) or train on a subset of the data in Colab to keep compute low, and the YOLO train mode docs show how to adjust these arguments.
ysharvit
I am looking for drone photos in desert area ( in order to develop rescue detection system (I volunteer in SAR unit)) Can I filter only desert BG pictures in your dataset?
- Glenn JocherUltralytics(تم التعديل)
VisDrone doesn’t include scene/terrain metadata like “desert” (it’s largely urban/traffic), so there’s no built‑in way to filter for desert backgrounds; for SAR you’ll want to gather desert drone imagery and fine‑tune a COCO‑pretrained YOLO26 using the dataset setup in the Datasets Overview or manage it end‑to‑end with Ultralytics Platform datasets.
fardinabbasi
It would be very useful if someone could provide a list of pretrained YOLO models for the VisDrone dataset that are compatible with Ultralytics.
- Glenn JocherUltralytics(تم التعديل)
Ultralytics doesn’t currently maintain an official list of VisDrone‑trained checkpoints; the recommended path is to fine‑tune a COCO‑pretrained YOLO26 variant (e.g.,
yolo26s.pt)—see the available base weights on the YOLO26 models page.
lawyeh
Hello, the example and the yaml file pull from the object detection in images dataset (task 1). How can I train the model for object detection in video (task )?
- Glenn JocherUltralytics
For video object detection (Task 2) with VisDrone, you'll use the same YOLO training process but process video frames as individual images. Ensure your dataset paths in VisDrone.yaml point to the video task's frame sequences (organized as images), then train normally. Video inference can be done with
model.predict(source='video.mp4')after training. For video-specific annotations, verify they're converted to YOLO format per frame.1
SudhanshuBlaze
I trained yolov10x on VisDrone dataset with the below parameters, but I got the final
box_lossof1.97. I feel that model performed very poorly, do you know what might be the issue? Or what hyperparameters should I use?from ultralytics import YOLO # Load a model model = YOLO("yolov10x.pt") # load a pretrained model (recommended for training) # Train the model results = model.train(data="VisDrone.yaml", epochs=1000, imgsz=640, patience=250, project='visdrone', name='train', batch=-1)- Glenn JocherUltralytics
@SudhanshuBlaze it sounds like your model might be struggling with the complexity of the VisDrone dataset. First, ensure you're using the latest version of the Ultralytics package. You might also want to experiment with different learning rates, batch sizes, and augmentation techniques. Sometimes, reducing the learning rate or increasing the batch size can help stabilize training. Additionally, consider using early stopping to prevent overfitting. If the issue persists, reviewing the dataset for any inconsistencies or mislabeled data could also be beneficial. For more detailed guidance, you can refer to the VisDrone documentation.
mariem158
quelles sont les étapes pour télécharger roboflow100 sur google colab. je veux utiliser ce dataset pour faire la détection précise des véhicules filmés par des caméras ?
- Paula DerrengerUltralytics(تم التعديل)
@mariem158 bonjour!
Pour télécharger et utiliser le dataset Roboflow100 sur Google Colab pour la détection précise des véhicules, vous pouvez suivre les étapes ci-dessous. Cependant, il semble que vous ayez mentionné le dataset VisDrone dans votre commentaire, donc je vais également inclure des informations sur ce dataset.
Étapes pour télécharger Roboflow100 sur Google Colab
-
Installer les dépendances nécessaires:
!pip install roboflow -
Importer et configurer Roboflow:
from roboflow import Roboflow rf = Roboflow(api_key="YOUR_API_KEY") project = rf.workspace().project("roboflow100") dataset = project.version("1").download("yolov8") -
Configurer le dataset pour l'entraînement:
from ultralytics import YOLO

# Charger un modèle pré-entraîné
model = YOLO("yolo26n.pt")

# Entraîner le modèle
results = model.train(data=dataset.location + "/data.yaml", epochs=100, imgsz=640)
Utilisation du dataset VisDrone
Le dataset VisDrone est une excellente ressource pour la détection d'objets, le suivi d'objets et le comptage de foules dans des images et vidéos capturées par des drones. Voici comment vous pouvez l'utiliser avec YOLO26:
-
Télécharger et configurer le dataset VisDrone:
from ultralytics import YOLO # Charger un modèle pré-entraîné model = YOLO("yolo26n.pt") # Entraîner le modèle results = model.train(data="VisDrone.yaml", epochs=100, imgsz=640) -
YAML de configuration pour VisDrone:
# Ultralytics YOLO 🚀, AGPL-3.0 license
# VisDrone2019-DET dataset https://github.com/VisDrone/VisDrone-Dataset by Tianjin University
path: ../datasets/VisDrone
train: VisDrone2019-DET-train/images
val: VisDrone2019-DET-val/images
test: VisDrone2019-DET-test-dev/images
names:
  0: pedestrian
  1: people
  2: bicycle
  3: car
  4: van
  5: truck
  6: tricycle
  7: awning-tricycle
  8: bus
  9: motor
Pour plus de détails sur l'utilisation du dataset VisDrone, vous pouvez consulter la documentation complète ici : VisDrone Dataset Documentation.
N'hésitez pas à revenir vers nous si vous avez d'autres questions! 😊
Cordialement, L'équipe Ultralytics
-
comment intégrer visdataset sur google colab et l'intégrer dans mon code qui détecte seulement des véhicules par des drones situé verticalement au dessus de la route.
- Paula DerrengerUltralytics(تم التعديل)
Bonjour,
Merci pour votre question ! Pour intégrer le dataset VisDrone dans Google Colab et l'utiliser pour détecter uniquement des véhicules capturés par des drones, voici les étapes à suivre :
-
Configurer Google Colab:
- Assurez-vous d'avoir accès à un GPU pour accélérer l'entraînement. Allez dans
Runtime>Change runtime typeet sélectionnezGPU.
- Assurez-vous d'avoir accès à un GPU pour accélérer l'entraînement. Allez dans
-
Installer les dépendances:
- Installez les bibliothèques nécessaires, notamment
ultralyticspour YOLO26.
- Installez les bibliothèques nécessaires, notamment
-
Télécharger et préparer le dataset VisDrone:
- Utilisez le script de téléchargement et de conversion fourni dans le fichier
VisDrone.yaml.
- Utilisez le script de téléchargement et de conversion fourni dans le fichier
-
Entraîner le modèle:
- Chargez un modèle pré-entraîné YOLO26 et entraînez-le sur le dataset VisDrone en filtrant uniquement les classes de véhicules.
Voici un exemple de code pour chaque étape :
# Installer les dépendances
!pip install ultralytics

# Importer les bibliothèques nécessaires
from ultralytics import YOLO
import os
from pathlib import Path

# Télécharger et préparer le dataset VisDrone
def download_visdrone():
    from ultralytics.utils.downloads import download

    def visdrone2yolo(dir):
        from PIL import Image
        from tqdm import tqdm

        def convert_box(size, box):
            dw = 1. / size[0]
            dh = 1. / size[1]
            return (box[0] + box[2] / 2) * dw, (box[1] + box[3] / 2) * dh, box[2] * dw, box[3] * dh

        (dir / 'labels').mkdir(parents=True, exist_ok=True)
        pbar = tqdm((dir / 'annotations').glob('*.txt'), desc=f'Converting {dir}')
        for f in pbar:
            img_size = Image.open((dir / 'images' / f.name).with_suffix('.jpg')).size
            lines = []
            with open(f, 'r') as file:
                for row in [x.split(',') for x in file.read().strip().splitlines()]:
                    if row[4] == '0':
                        continue
                    cls = int(row[5]) - 1
                    box = convert_box(img_size, tuple(map(int, row[:4])))
                    lines.append(f"{cls} {' '.join(f'{x:.6f}' for x in box)}\n")
                with open(str(f).replace(f'{os.sep}annotations{os.sep}', f'{os.sep}labels{os.sep}'), 'w') as fl:
                    fl.writelines(lines)

    dir = Path('../datasets/VisDrone')
    urls = [
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-train.zip',
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-val.zip',
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-test-dev.zip',
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-test-challenge.zip'
    ]
    download(urls, dir=dir, curl=True, threads=4)
    for d in ['VisDrone2019-DET-train', 'VisDrone2019-DET-val', 'VisDrone2019-DET-test-dev']:
        visdrone2yolo(dir / d)

download_visdrone()

# Entraîner le modèle YOLO26 sur le dataset VisDrone
model = YOLO("yolo26n.pt")  # Charger un modèle pré-entraîné
results = model.train(data="VisDrone.yaml", epochs=100, imgsz=640)
Pour plus de détails sur la configuration du dataset et les options d'entraînement, vous pouvez consulter la documentation complète ici.
N'hésitez pas à revenir vers nous si vous avez d'autres questions. Bonne chance avec votre projet ! 🚀
Cordialement, L'équipe Ultralytics
-
comment je peux utiliser les modèles de visdrone et faire l'appel à ce dataset dans mon code pour faire la détection des véhicules par mon drone?
- Paula DerrengerUltralytics(تم التعديل)
Bonjour,
Merci pour votre question ! Pour utiliser le dataset VisDrone et détecter uniquement les véhicules capturés par des drones, voici comment procéder sur Google Colab :
-
Configurer Google Colab:
- Assurez-vous d'avoir accès à un GPU pour accélérer l'entraînement. Allez dans
Runtime>Change runtime typeet sélectionnezGPU.
- Assurez-vous d'avoir accès à un GPU pour accélérer l'entraînement. Allez dans
-
Installer les dépendances:
- Installez les bibliothèques nécessaires, notamment
ultralyticspour YOLO26.
- Installez les bibliothèques nécessaires, notamment
-
Télécharger et préparer le dataset VisDrone:
- Utilisez le script de téléchargement et de conversion fourni dans le fichier
VisDrone.yaml.
- Utilisez le script de téléchargement et de conversion fourni dans le fichier
-
Entraîner le modèle:
- Chargez un modèle pré-entraîné YOLO26 et entraînez-le sur le dataset VisDrone en filtrant uniquement les classes de véhicules.
Voici un exemple de code pour chaque étape :
# Installer les dépendances
!pip install ultralytics

# Importer les bibliothèques nécessaires
from ultralytics import YOLO
import os
from pathlib import Path

# Télécharger et préparer le dataset VisDrone
def download_visdrone():
    from ultralytics.utils.downloads import download

    def visdrone2yolo(dir):
        from PIL import Image
        from tqdm import tqdm

        def convert_box(size, box):
            dw = 1. / size[0]
            dh = 1. / size[1]
            return (box[0] + box[2] / 2) * dw, (box[1] + box[3] / 2) * dh, box[2] * dw, box[3] * dh

        (dir / 'labels').mkdir(parents=True, exist_ok=True)
        pbar = tqdm((dir / 'annotations').glob('*.txt'), desc=f'Converting {dir}')
        for f in pbar:
            img_size = Image.open((dir / 'images' / f.name).with_suffix('.jpg')).size
            lines = []
            with open(f, 'r') as file:
                for row in [x.split(',') for x in file.read().strip().splitlines()]:
                    if row[4] == '0':
                        continue
                    cls = int(row[5]) - 1
                    box = convert_box(img_size, tuple(map(int, row[:4])))
                    lines.append(f"{cls} {' '.join(f'{x:.6f}' for x in box)}\n")
                with open(str(f).replace(f'{os.sep}annotations{os.sep}', f'{os.sep}labels{os.sep}'), 'w') as fl:
                    fl.writelines(lines)

    dir = Path('../datasets/VisDrone')
    urls = [
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-train.zip',
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-val.zip',
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-test-dev.zip',
        'https://github.com/ultralytics/yolov5/releases/download/v1.0/VisDrone2019-DET-test-challenge.zip'
    ]
    download(urls, dir=dir, curl=True, threads=4)
    for d in ['VisDrone2019-DET-train', 'VisDrone2019-DET-val', 'VisDrone2019-DET-test-dev']:
        visdrone2yolo(dir / d)

download_visdrone()

# Entraîner le modèle YOLO26 sur le dataset VisDrone
model = YOLO("yolo26n.pt")  # Charger un modèle pré-entraîné
results = model.train(data="VisDrone.yaml", epochs=100, imgsz=640)
Pour plus de détails sur la configuration du dataset et les options d'entraînement, vous pouvez consulter la documentation complète ici.
N'hésitez pas à revenir vers nous si vous avez d'autres questions. Bonne chance avec votre projet ! 🚀
Cordialement, L'équipe Ultralytics
-
Elvis-Kiilu2
This is nice, but what's next after the detection? How do we send/retrieve the data to a given database? What further insights can we draw from the detected data? What other technologies can we intergrate to this to draw meaningful inferences??
- Paula DerrengerUltralytics(تم التعديل)
After detection, you have a few options to extend the functionality:
-
Data Storage: To send and store detections on a database:
import sqlite3 from datetime import datetime from ultralytics import YOLO # Connect to SQLite database connection = sqlite3.connect('my_detections.db') cursor = connection.cursor() # Create table cursor.execute('''CREATE TABLE IF NOT EXISTS detections (timestamp DATETIME, class TEXT, confidence REAL, x REAL, y REAL, width REAL, height REAL)''') # Example insertion from detection results = YOLO("yolo26n.pt")("image.jpg")[0] names = results.names timestamp = datetime.now().isoformat() for det in results.boxes: cursor.execute('''INSERT INTO detections (timestamp, class, confidence, x, y, width, height) VALUES (?, ?, ?, ?, ?, ?, ?)''', (timestamp, names[int(det.cls)], float(det.conf), *det.xywh[0].tolist())) connection.commit() connection.close() -
Further Analysis: Analyze the time series of detections to observe trends, detect anomalies, or aggregate counts over time.
-
Integration with Other Technologies: Integrate with IoT platforms for real-time alerts or incorporate AI-based services for enhanced image analysis and decision-making processes.
These steps help bridge the gap between raw detection outputs and actionable insights or responses in real-world applications.
-
Thanks @pderrenger for the reply. I wanted to implement this for my next project. Your insights are a good starting point. My aim is to extract/read data from the detected class/boxes. Then compare and match the read data with with those in a database that in a cloud data warehouse, Bigquery to be specific.
- Paula DerrengerUltralytics
Hey there! It's great to hear you're planning to use YOLOv8 for your project. To extract and compare data from detected objects with your BigQuery database, you can follow these steps:
-
Extract Data: After detection, extract the necessary details from each detection (like class, confidence, and bounding box coordinates).
-
Format Data: Convert this data into a suitable format (like JSON or CSV) that can be easily ingested into BigQuery.
-
Upload to BigQuery: Use the BigQuery API to upload your formatted data. Here’s a small Python snippet using
google-cloud-bigquery:from google.cloud import bigquery # Construct a BigQuery client object. client = bigquery.Client() # Define your table ID (dataset.table) table_id = "your-project.your_dataset.your_table" # Define the data to be inserted rows_to_insert = [ {u"class": detected_class, u"confidence": confidence, u"x_min": x_min, u"y_min": y_min, u"width": width, u"height": height} ] # Insert data into BigQuery errors = client.insert_rows_json(table_id, rows_to_insert) if errors == []: print("New rows have been added.") -
Query and Analyze: Once your data is in BigQuery, you can use SQL queries to compare, analyze, and draw insights based on your specific needs.
This workflow will help you leverage the power of cloud computing to analyze large datasets efficiently. If you need further assistance or have more specific requirements, feel free to ask! 🚀
-